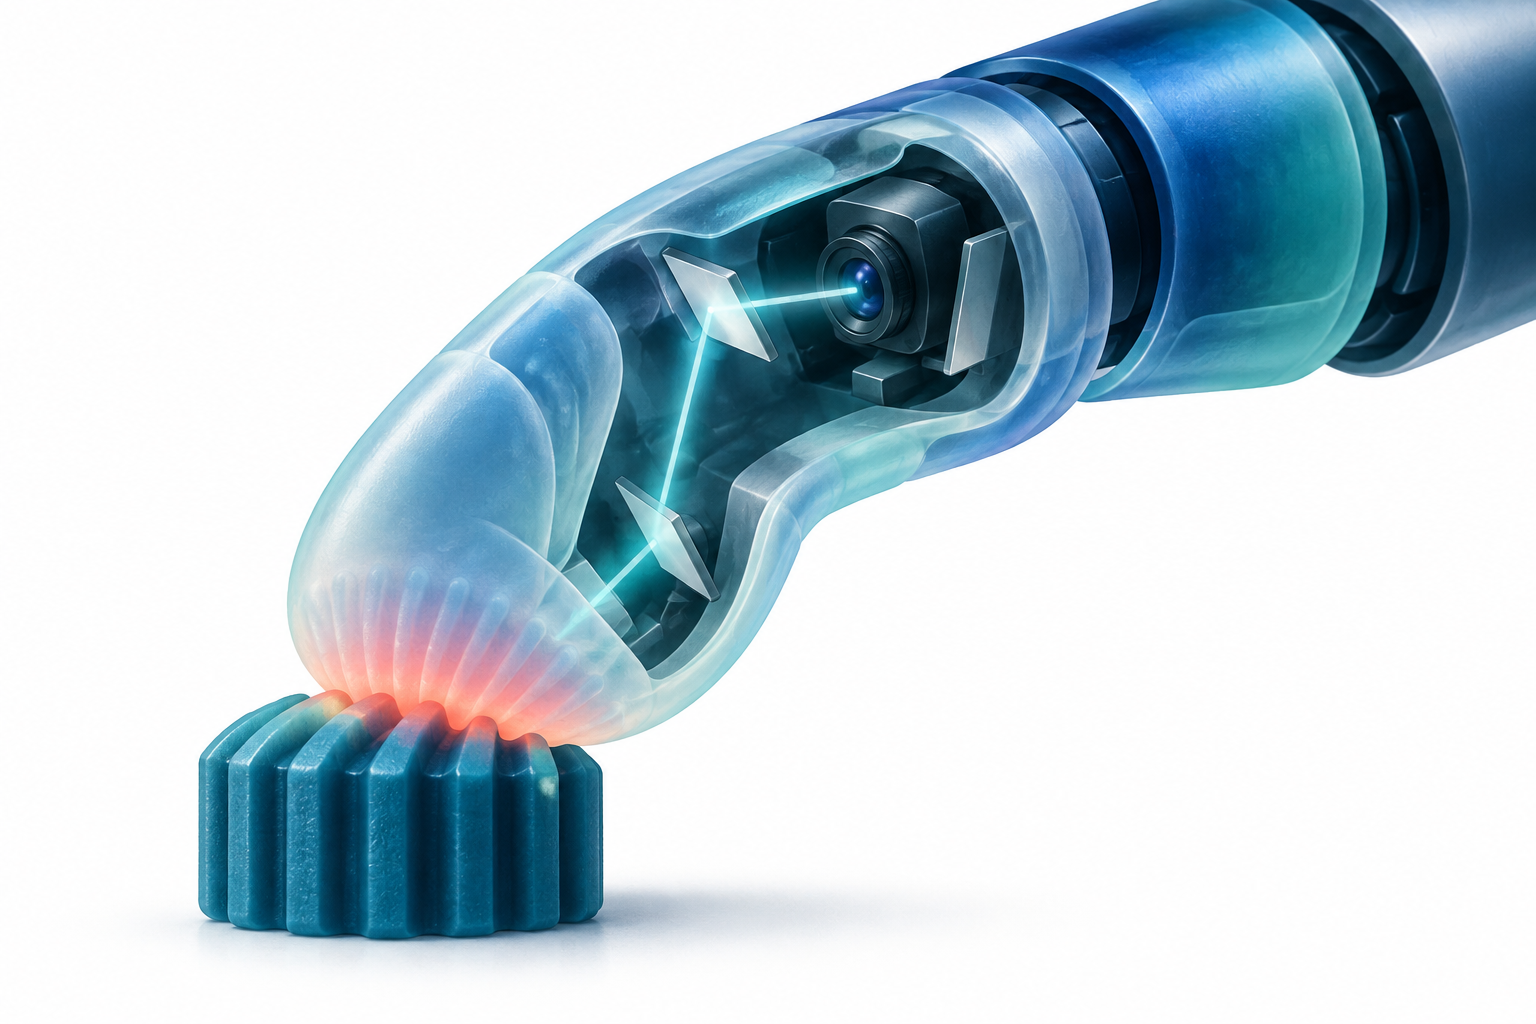
Test the surroundings too
NASA’s September 28, 2026 report describes iMETRO, a ground facility for adapting robots to human-supervised space tasks. It combines simulation tools with physical habitat mockups and robots. The agency says robot developers and habitat designers can learn from one another: a larger handle or better lighting may help both robots and people. [1]
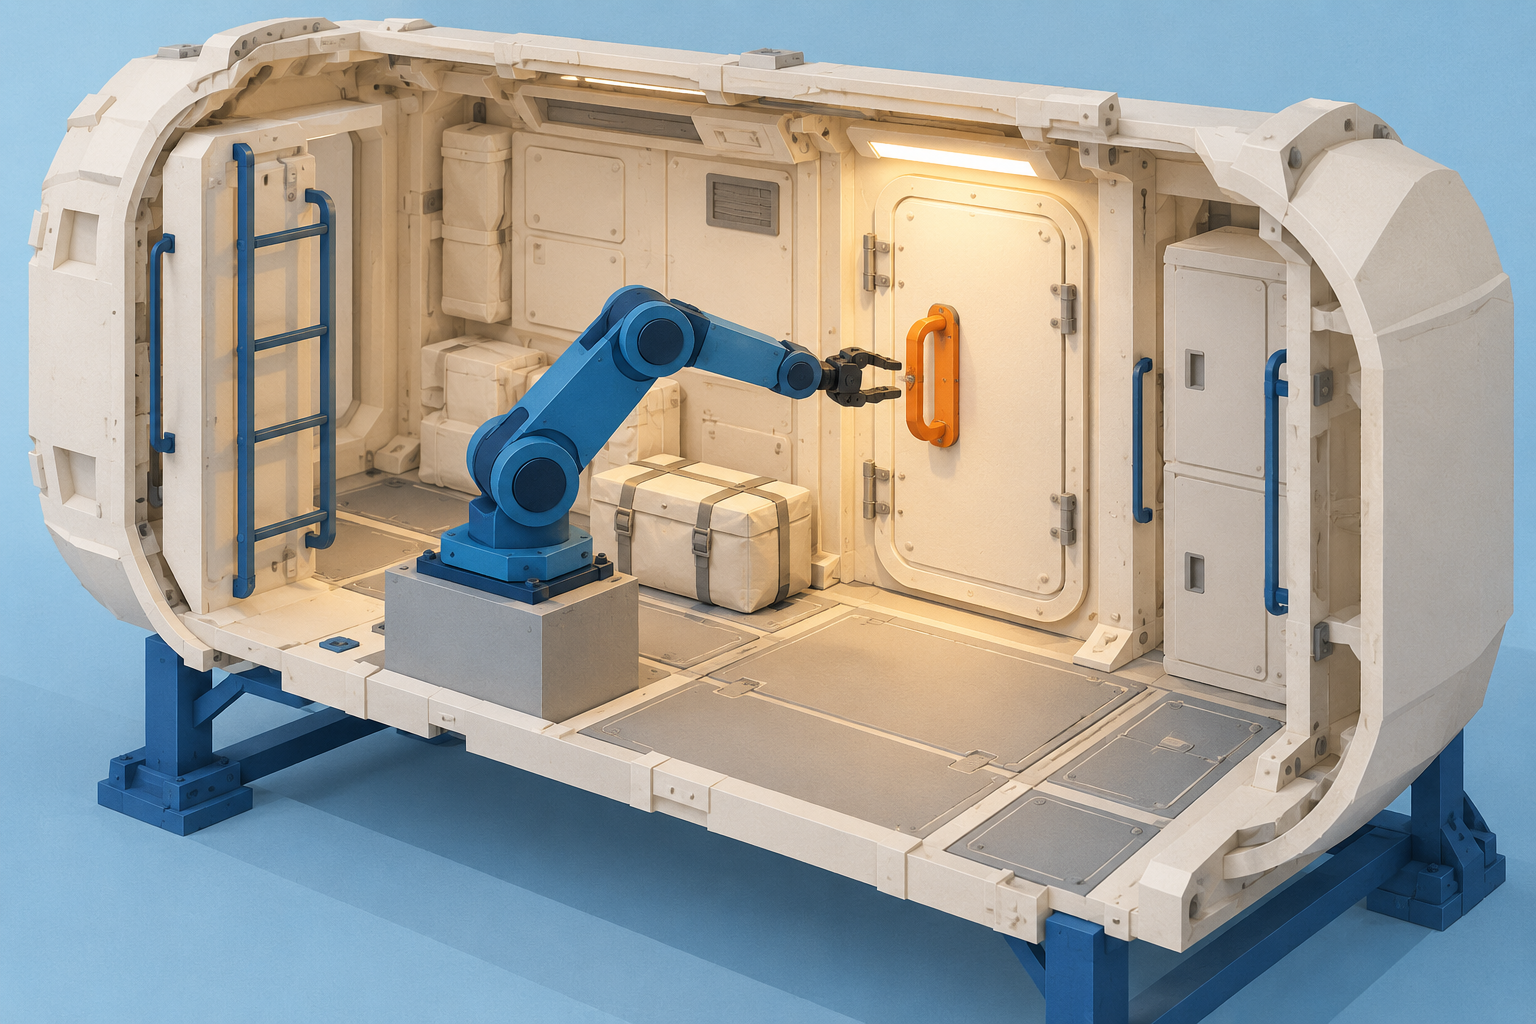
A hatch becomes a task
NASA reports that a PickNik team tested an arm recognizing a hatch, operating its latch and handle, opening it, and transferring cargo bags. This is a concrete ground demonstration, not evidence of an autonomous robot maintaining a lunar habitat. [1]
Ask which part needs changing
Hypothetical example: An arm reaches a cupboard but cannot approach a small recessed handle without hitting the door. One experiment could change the gripper; another could change the handle. Comparing them tests the whole task rather than assuming the robot alone must absorb every design constraint. This example is invented, not an iMETRO result.
Go a little deeper
Optional reading · about 1 more minute
Digital models and physical equipment
The facility’s public documentation lists robot configurations, simulated environments, hardware interfaces and mockups for hatch and cargo tasks. It distinguishes software used with physical hardware from simulation. It also marks configurable network latency and bandwidth restrictions as a future planned facility capability; the repository is not evidence that every listed ambition is already available. [2]
A useful limit on the claim
Our interpretation: A successful demonstration answers a bounded question about a task and setup. To judge readiness for a mission, ask what was varied, what human assistance remained, and how failure was handled. A room that works for one test is a starting point for those questions, not their answer.
Original sources
Attributed synthesis, not original reporting. Examples labeled hypothetical or illustrative are explanatory. Reviewing a source does not independently validate its findings.
- NASA: Reliable Robots ↗
September 28, 2026 institutional report; iMETRO, design collaboration and hatch example read September 30. No independent replication.
- NASA-JSC-Robotics: iMETRO documentation ↗
README read September 30, 2026; facility features, software and explicit planned network capability. Repository not run.